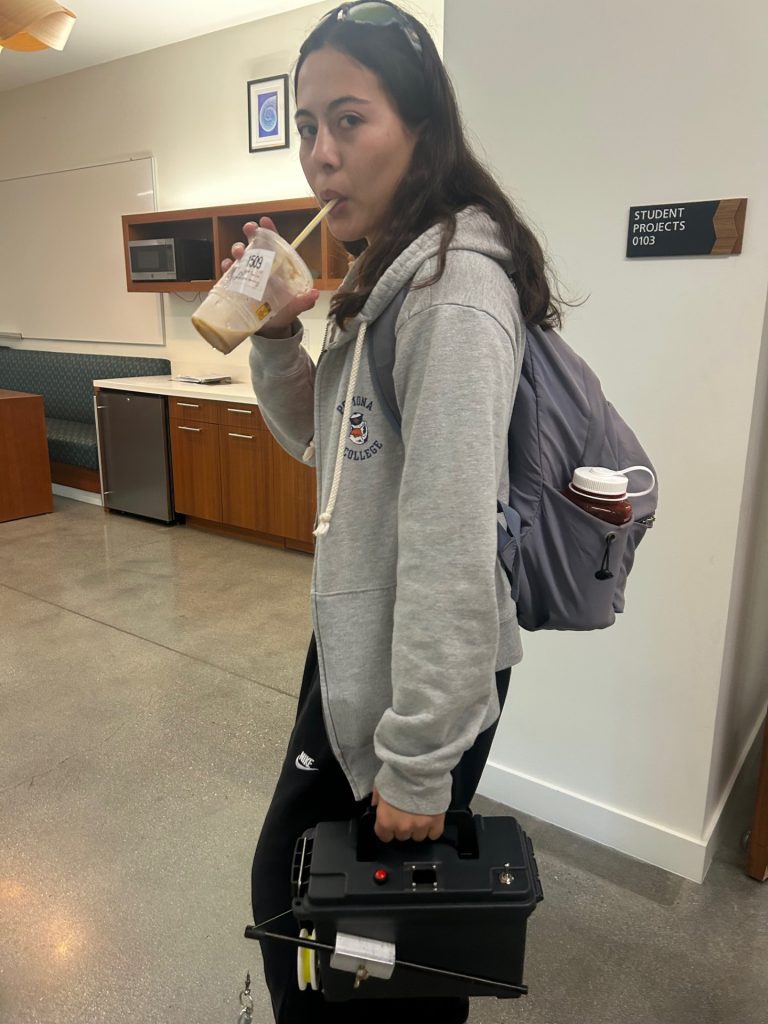
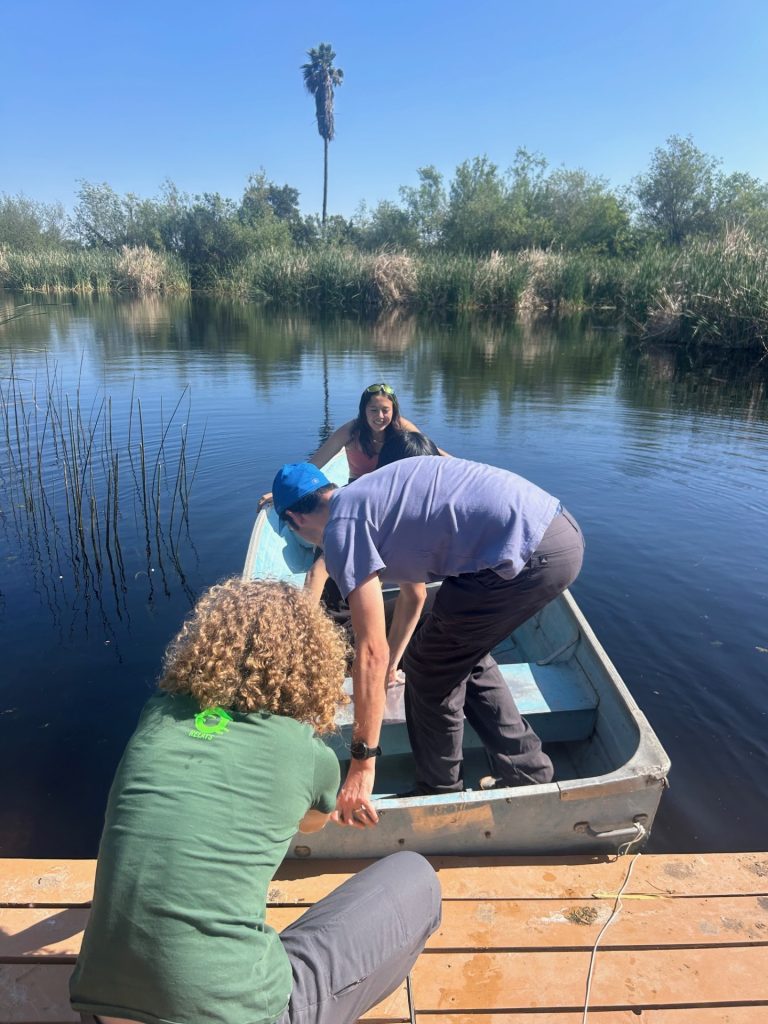
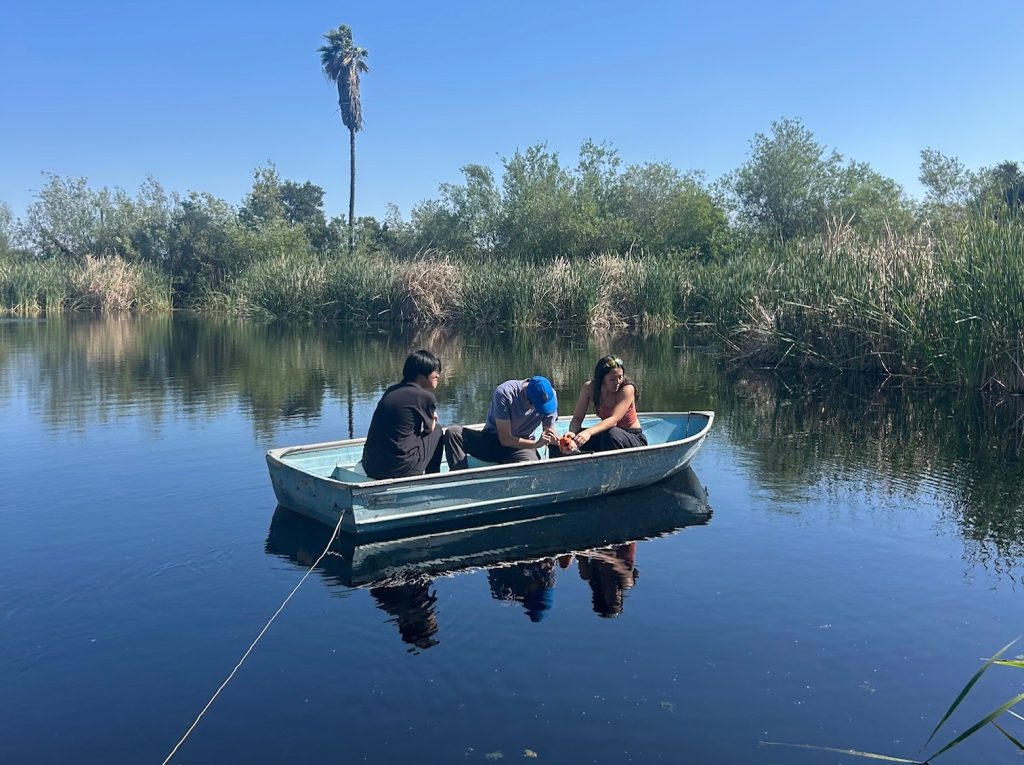
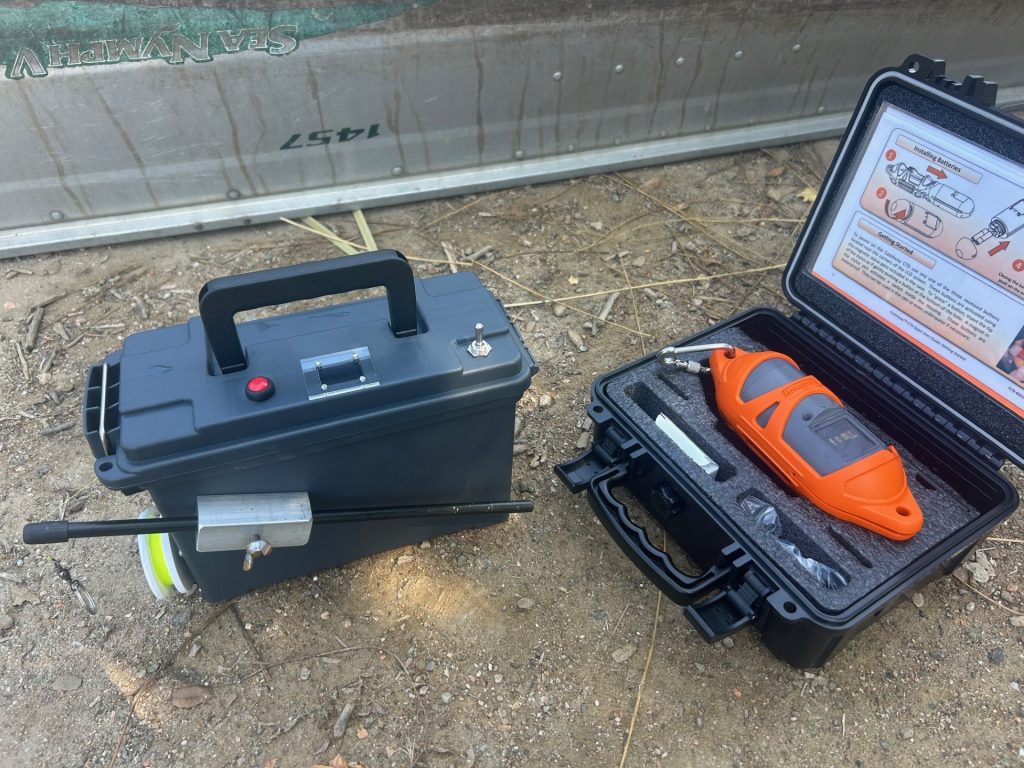
Figure 1: The automated winch after its first pHake Lake trial
Background & Mission

Figure 2: Winch Examples
“to try and build a winch type thing that could work off a boat or kayak”
-Professor Robert Sanchez of HMC
Patricia is a member of Professor Sanchez’s research group studying estuary dynamics.
CTD (Conductivity, Temperature, and Depth) devices are commonly used in this area
of research to examine observables in these environments. Initially, Professor Sanchez planned to use
a fishing rod to hoist the CTD, but with the development of our Arduino-controlled winch,
we obtain accurate depth readouts while raising and lowering the CTD securely.
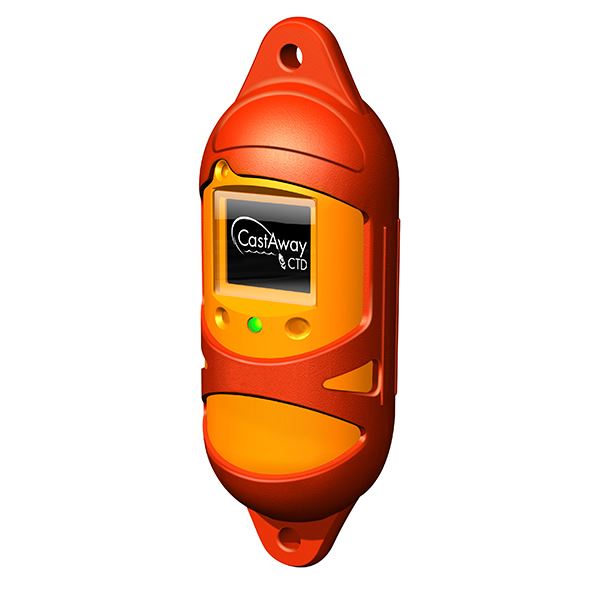
Figure 3: The SonTek CastAway-CTD
Electronics

UCTRONICS 0.96 Inch OLED Module Display
Arduino Uno
Nema23 stepper motor
TB6600 Current driver
DC-DC Buck Converter
18V Rechargeable Battery
3 Way Switch
Red Calibration Button
Figure 4: Patricia’s Circuit Diagram
Mechanical Design
Components

- Fishing Line
- Aluminum Rod Fixer
- 3D Printed Bushing
- Swivel
- Carabiner
- Plastic Toolbox Base
- Clear Acrylic Display Cover
- Rod
- Spool
Arduino Code
### Arduino IDE Code for Corrina & Patricia's winch ###

### PACKAGES ###
#include <Wire.h>
#include <Adafruit_GFX.h>
#include <Adafruit_SSD1306.h>

### PINOUTS ###
#define SCREEN_WIDTH 128
#define SCREEN_HEIGHT 64
#define OLED_RESET -1
#define YELLOW_HEIGHT 16
#define BUTTON_PIN 7
#define SWITCH_UP_PIN 9
#define SWITCH_DOWN_PIN 8

const int stepPin = 3;
const int dirPin = 2;

### SPOOL DETAILS ###
const float R0 = 31.44;           // outer radius of spool in mm
const int PULSES_PER_REV = 21286;

### DEPTH CALCULATION & DISPLAY ###
Adafruit_SSD1306 display(SCREEN_WIDTH, SCREEN_HEIGHT, &Wire, OLED_RESET);

volatile long stepCount = 0;
float displayDepth = 0.0;
float lastDisplayDepth = -1.0;
int lastButtonState = HIGH;

void countStep() {
 if(digitalRead(dirPin) == HIGH)
     stepCount++;   // unwinding = going deeper
 else
     stepCount--;   // winding = coming up
}

float calculateDepth() {
  float theta = (float)stepCount / PULSES_PER_REV;
  float depth_m = (2.0 * PI * R0 * theta) / 1000.0;

  // Exponential correction factor
  return depth_m * (1.0 - (0.00000001 * depth_m * depth_m));
}

void invertSection(int16_t y_start, int16_t y_end) {
 display.fillRect(0, y_start, SCREEN_WIDTH, y_end - y_start, SSD1306_INVERSE);
}


void updateDisplay(float depth) {
 display.clearDisplay();


 // Yellow section — "Depth" label
 display.setTextSize(1);
 display.setTextColor(SSD1306_WHITE);
 display.setCursor(50, 4);
 display.println(F("Depth"));
 invertSection(0, YELLOW_HEIGHT);


 // Blue section — depth reading
 display.setTextSize(2);


 // Format as X.XX m
 char depthStr[10];
 dtostrf(depth, 4, 2, depthStr);
 strcat(depthStr, "m");


 // Center the text
 int16_t x1, y1;
 uint16_t w, h;
 display.getTextBounds(depthStr, 0, 0, &x1, &y1, &w, &h);
 display.setCursor((SCREEN_WIDTH - w) / 2, 35);
 display.println(depthStr);


 display.display();
}


void setup() {
 pinMode(stepPin, OUTPUT);
 pinMode(dirPin, OUTPUT);
 pinMode(BUTTON_PIN, INPUT_PULLUP);
 pinMode(SWITCH_UP_PIN, INPUT_PULLUP);
 pinMode(SWITCH_DOWN_PIN, INPUT_PULLUP);


 digitalWrite(dirPin, HIGH);


 // Attach an interrupt to pin 3 (PUL) to count every step pulse
 attachInterrupt(digitalPinToInterrupt(3), countStep, RISING);


 // Timer2 PWM on pin 3
 TCCR2A = _BV(COM2B1) | _BV(WGM21) | _BV(WGM20);
 TCCR2B = _BV(CS21);      // Keep original prescaler
 OCR2B = 64;              // Keep original value
 // Keep this line - it disables PWM at startup
 TCCR2A &= ~_BV(COM2B1);


 if(!display.begin(SSD1306_SWITCHCAPVCC, 0x3C)) {
     for(;;);
 }


 updateDisplay(0.0);
}


void loop() {
 int buttonState = digitalRead(BUTTON_PIN);
 int switchUpState = digitalRead(SWITCH_UP_PIN);
 int switchDownState = digitalRead(SWITCH_DOWN_PIN);


 // Red calibration button resets depth to 0
 if(buttonState == LOW && lastButtonState == HIGH) {
     stepCount = 0;
     updateDisplay(0.0);
     delay(50);

 lastButtonState = buttonState;


 // Motor direction + start/stop
 if(switchUpState == LOW) {
     TCCR2A &= ~_BV(COM2B1);
     digitalWrite(dirPin, HIGH);
     delayMicroseconds(1);
     TCCR2A |= _BV(COM2B1);
 } else if(switchDownState == LOW) {
     TCCR2A &= ~_BV(COM2B1);
     digitalWrite(dirPin, LOW);
     delayMicroseconds(1);
     TCCR2A |= _BV(COM2B1);
 } else {
     TCCR2A &= ~_BV(COM2B1);
     digitalWrite(stepPin, LOW);
 }

 // Update display only when depth changes by 0.01m
 displayDepth = calculateDepth();
 if(abs(displayDepth - lastDisplayDepth) >= 0.01) {
     updateDisplay(displayDepth);
     lastDisplayDepth = displayDepth;
 }

 delay(10);
}
Data
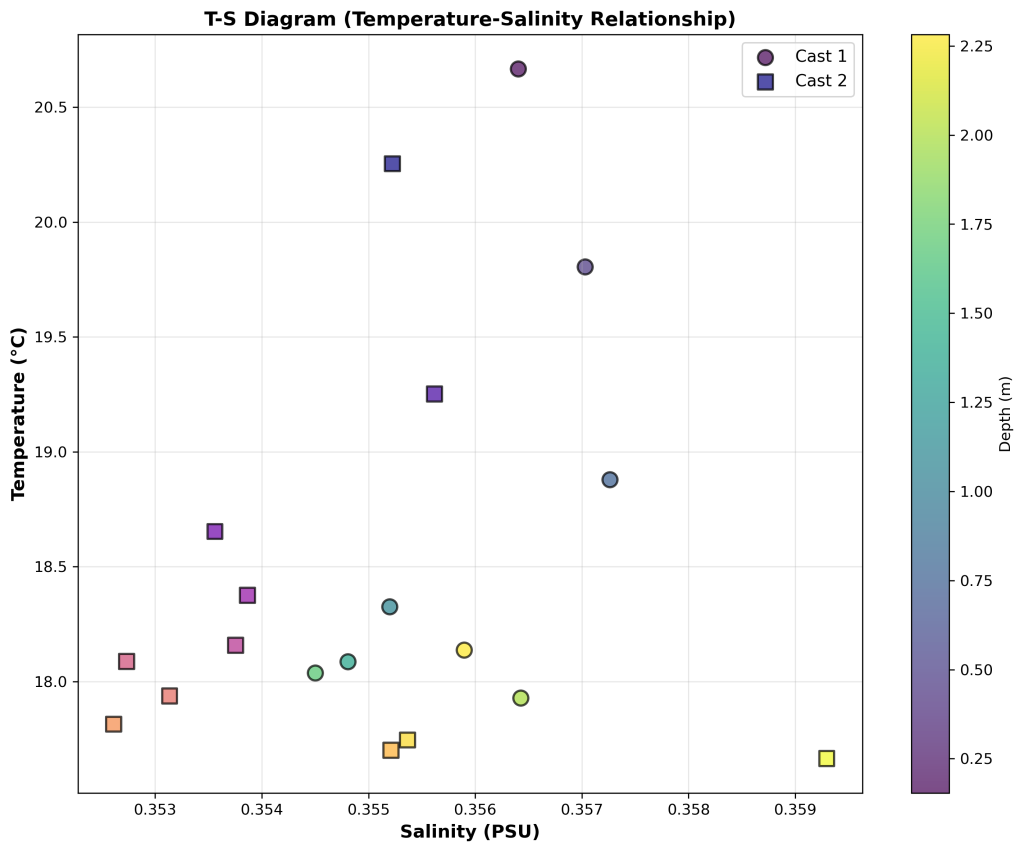
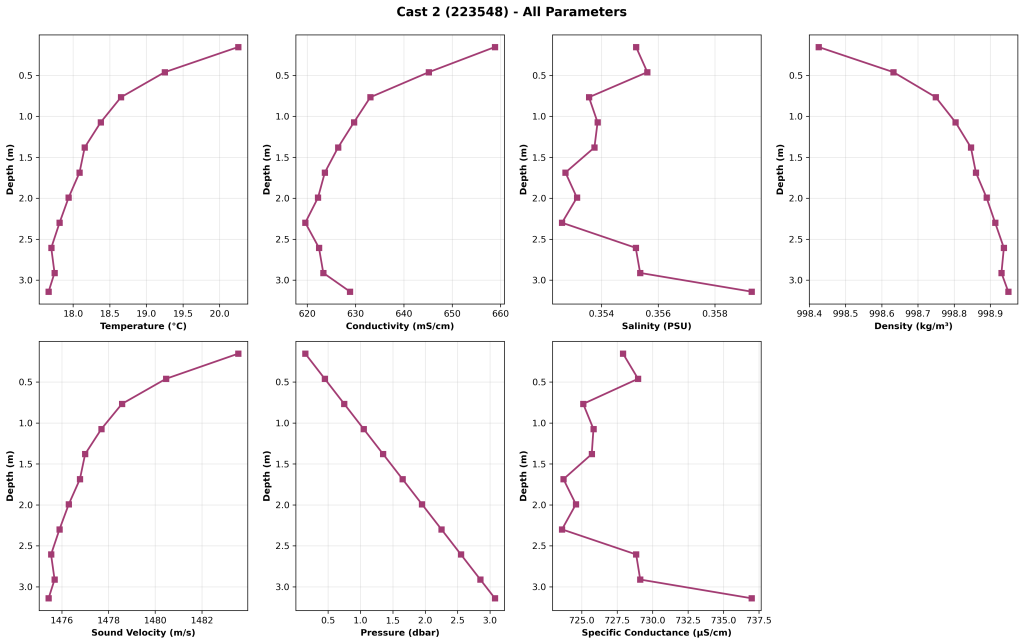
Goodies from pHake Lake